
The main function of the micro reduction motor
Micro gear motor main function The micro gear motor refers to the integration of a reducer and a motor (motor), which can also be called a gear micro reducer motor or gear motor. It is basically supplied as a complete set after being integrated and assembled by the reducer manufacturer.
Release time:
2022-09-29 10:19
Micro gear motorMain functions
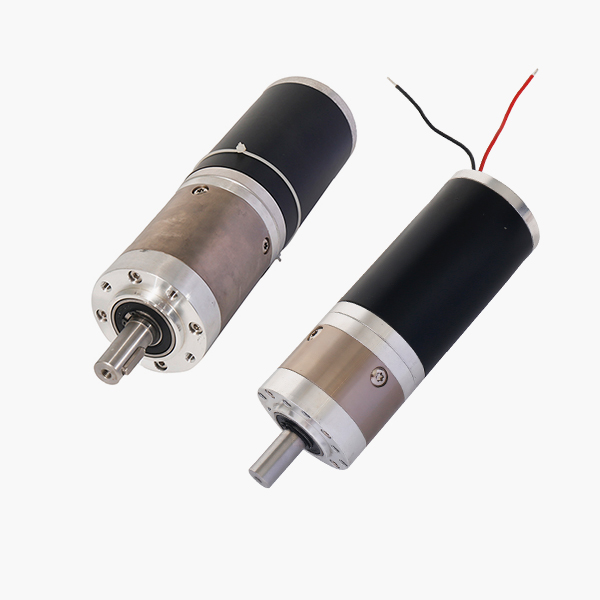
Micro gear motor, refers to the integration of the reducer and the motor (motor), which can also be called gear micro gear motor or gear motor, and is basically supplied by the reducer manufacturer after integrated assembly.
The working principle of the micro gear motor is to reduce the speed significantly through the motor's power via the gear (or worm gear) reducer, thereby increasing the motor's output torque to meet the needs of mechanical equipment operation. This power transmission device has a core effect that cannot be ignored - the "reduction" effect, which achieves the purpose of deceleration by using various levels of gears (or worm gears) for transmission. The reducer is composed of various levels of gear pairs.
The micro gear motor mainly has the following three functions: Deceleration: The motor speed reaches the required speed through the reduction gearbox, that is, the output speed; Increase torque: Under the same power conditions, the slower the output speed of the gear micro gear motor, the greater the torque, and vice versa; Change the transmission direction: For example, the bevel gear micro gear motor can transmit torque vertically at 90 degrees. Among them, the reducer provides a lower speed and greater torque; at the same time, different reduction ratios can provide different speeds and torques. Different industries usually use DC micro gear motors of different powers, generally adopting a customized power design model. (Compared to ordinary motors, micro gear motors have an additional matching gear reducer.)
Micro gear motorDue to the high integration, it has many excellent characteristics: the micro gear motor has a compact structure, small length, and small volume; the transmission ratio is finely graded, with a wide selection range and a broad speed spectrum; superior performance, low energy consumption, and the mechanical efficiency of the gearbox can reach 94%; strong versatility, easy disassembly and maintenance, and low maintenance costs; a brand new sealing device with good protection performance and strong environmental adaptability; from the internal structure, (from right to left) the planetary reducer is roughly composed of several parts: motor side (input side) bearing, motor side flange, input shaft, planetary gear set, output shaft, output side (load side) flange, and load side bearing.
In the middle of this series of components is the core transmission component that any planetary reducer must be equipped with: the planetary gear set. In the structure of the planetary gear set, several gears surround a central gear on the inner circle of the reducer housing. When the planetary reducer operates, as the central gear rotates, the surrounding gears also "rotate" around the central gear. Because the layout of the core transmission device is very similar to the way planets in our solar system orbit the sun, the reducer is called a "planetary reducer." The central gear, usually referred to as the "sun gear," is driven by the input servo motor through the input shaft. The multiple gears rotating around the sun gear are called "planet gears." One side of the gear meshes with the sun gear, while the other side meshes with the annular internal tooth circle on the inner wall of the reducer housing, bearing the torque power transmitted from the input shaft through the sun gear, and transmitting the power to the load end through the output shaft. During normal operation, the track is the annular internal tooth circle on the inner wall of the reducer housing.
Previous Page
Next Page
Related News
What is the difference between brushless reduction motors and brushed reduction motors?
Brushless DC Motor (BLDC) and Brushed DC Motor have some significant differences in structure, working principle, performance, and other aspects. Here are their main differences:
How to assess the noise level and vibration characteristics of a screw-type window opener motor?
When selecting a screw-type window opener motor, its noise level and vibration characteristics are two crucial factors that directly affect the user experience and the stability of the equipment. So, how should we evaluate these two aspects?
In the field of construction, screw-type window openers are important devices for achieving automated window opening and closing, and their performance and stability are crucial. Especially in some harsh environmental conditions, such as high humidity and dusty places, the protection level of the motor becomes a key factor in ensuring the normal operation of the window opener.
What are the common faults of screw-type window opener motors?
The screw-type window opener motor may experience some common faults during long-term use. Below are some typical fault phenomena and their possible causes.
Introduction to Micro DC Gear Motors
Introduction to Micro DC Gear Motors Micro DC gear motors are a miniaturized motor system, typically consisting of a DC motor and a gearbox. Here are some related introductions to micro DC gear motors: DC Motor Section: Working Principle: The DC motor generates current by moving a conductive coil in a magnetic field, thus producing electromagnetic force to drive the motor's rotation. Structure: Micro DC motors usually adopt a separate structure, including an armature (rotating part) and an electromagnet (stator part). Types: Common types of DC motors include brushed DC motors and brushless DC motors. Brushed DC motors use brushes to connect to the armature, while brushless DC motors control current through an electronic speed controller, eliminating the need for brushes. Gearbox Section: Function: The gearbox is used to slow down the motor's output speed while increasing torque. This is crucial for applications requiring higher torque and lower speeds, such as robotic arms and camera gimbals. Structure: Gearboxes typically consist of gears that achieve the reduction ratio through different gear combinations. The reduction ratio is the ratio of input speed to output speed. Types: Common types of gearboxes include planetary gears, worm gears, and helical gears. Different types of gearboxes are suitable for different application scenarios. Applications: Micro DC gear motors are widely used in various fields, including consumer electronics (such as cameras and printers), medical devices, robotics, and automotive electronics. In these applications, micro DC gear motors are typically used to control precise movements, provide sufficient torque, and achieve efficient performance in limited spaces. Control and Drive: Micro DC gear motors usually require corresponding electronic speed controllers or controllers to precisely control rotation speed and direction. The control system can adjust the motor's output according to application needs, achieving precise position control and speed regulation. Performance Parameters: The performance parameters of micro DC gear motors include rated voltage, rated speed, rated torque, efficiency, etc. These parameters are crucial for selecting and designing motor systems. In summary, micro DC gear motors have been widely applied under the trends of miniaturization, precision, and efficiency, providing reliable driving force for many electric devices and systems.
Contact Information
Service Hotline:+86 0769-3901 7383
Mobile Phone: +86 180 0260 1103
Email: sunweihong@silentgear.cn
Factory Address: No. 15, Century Road, Baihao Industrial Zone, Houjie Town, Dongguan City, Guangdong Province
Quick Navigation
Online message
Contact Us

COPYRIGHT 2024 Dongguan Silent Industrial Co., Ltd.